Hi, I'm
Maaz Qureshi
Research Engineer · Embodied AI & Robot Learning
Embodied AI
Robot Learning
Policy Learning (RL / VLA)
Perception & Manipulation
Hi, I'm
Research Engineer · Embodied AI & Robot Learning
Get To Know More
I'm a Research Engineer focused on Embodied AI and robot learning, teaching robots to perceive, reason, and act in the physical world. My work spans learned control policies (reinforcement learning, VLA, and imitation learning), multimodal and foundation models (CNNs, VLMs, VLAs, and world-action models), and the real-time systems that deploy them on multi-robot platforms.
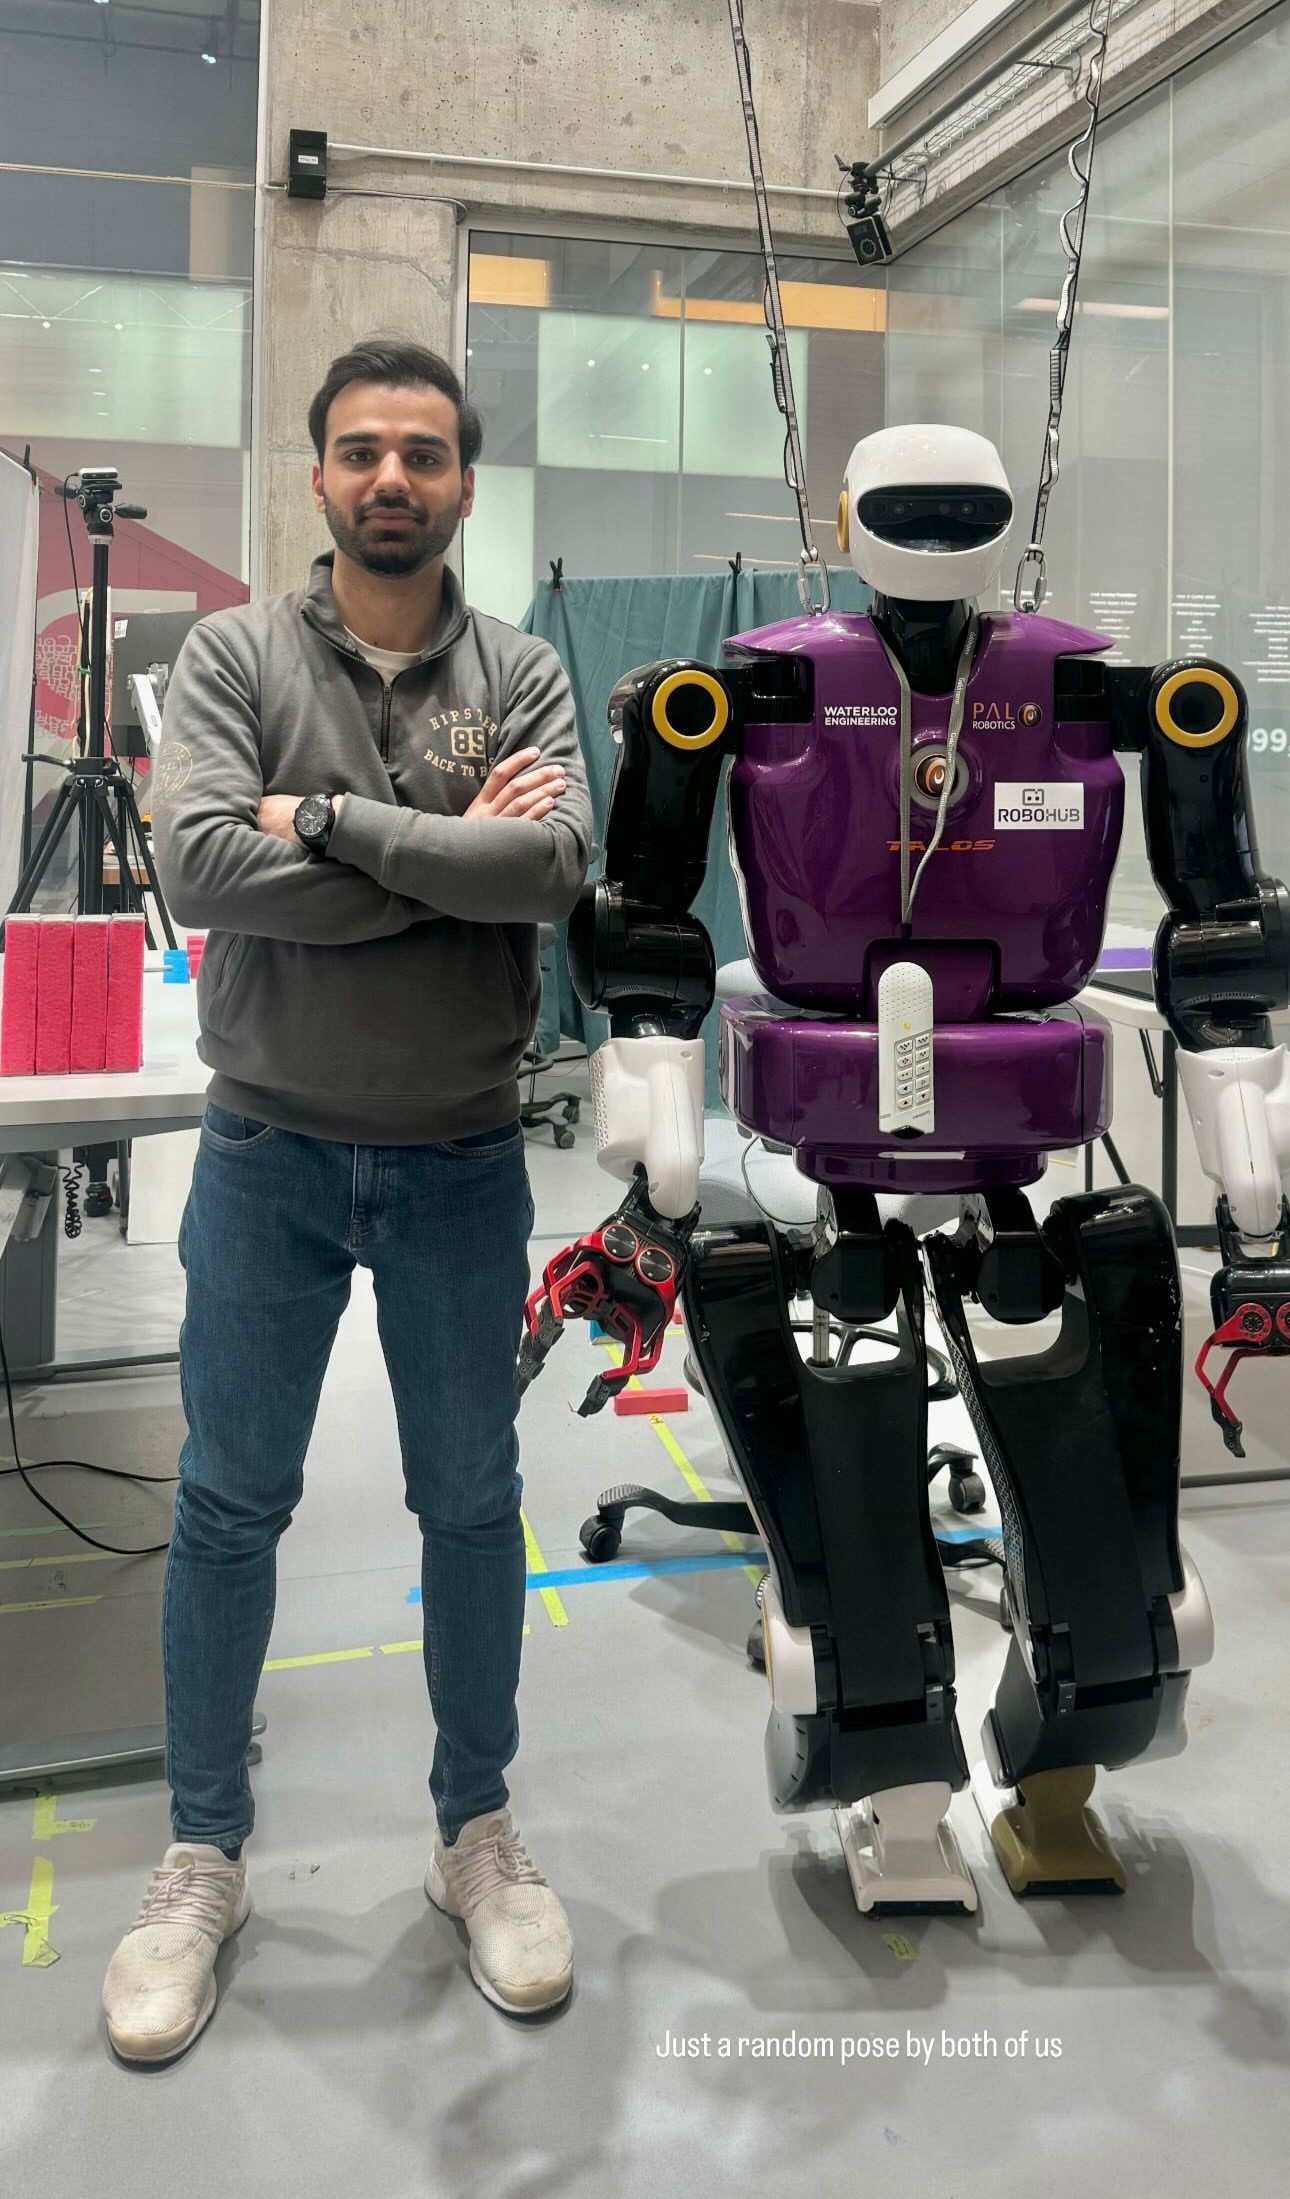
During my research at the University of Waterloo, I worked with Dr. William Melek and Dr. George Shaker, collaborating with Apple, UW RoboHub, Keysight, and Rogers on smart-factory robotics.
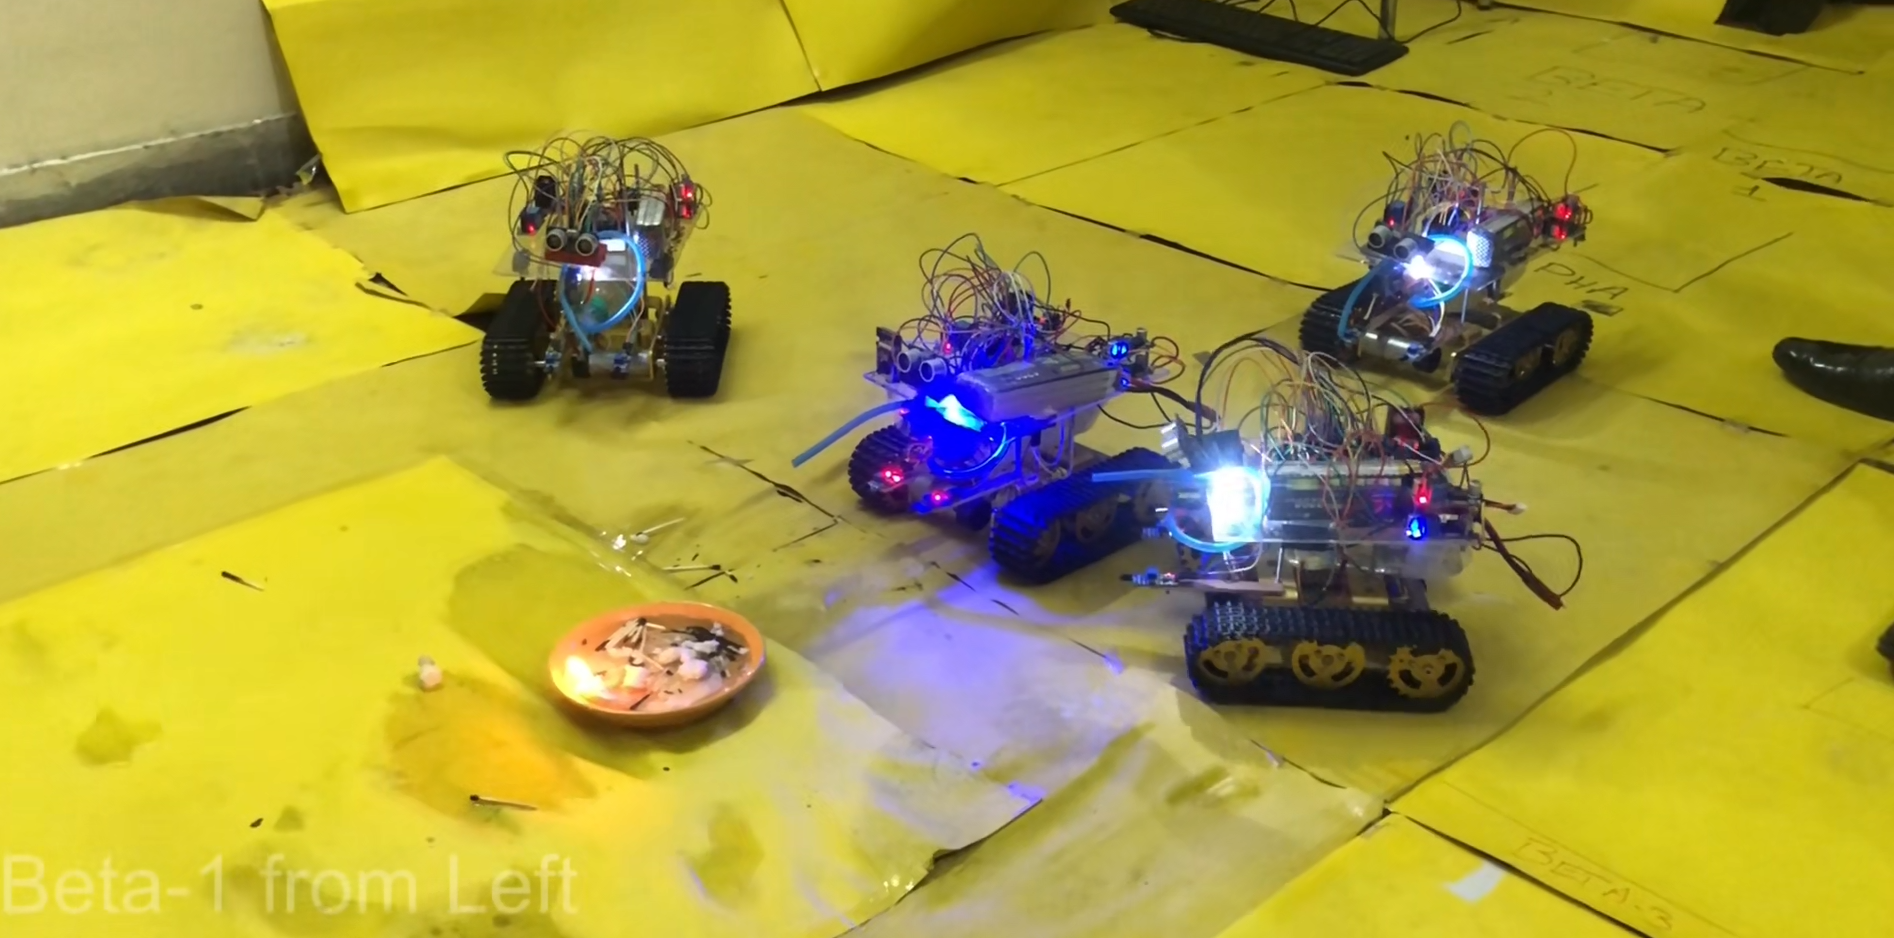
My fascination with autonomy started early: I built a swarm-robotics system that won 3rd place for Best Engineering Project at the national level.
Jan 2024 – Aug 2025
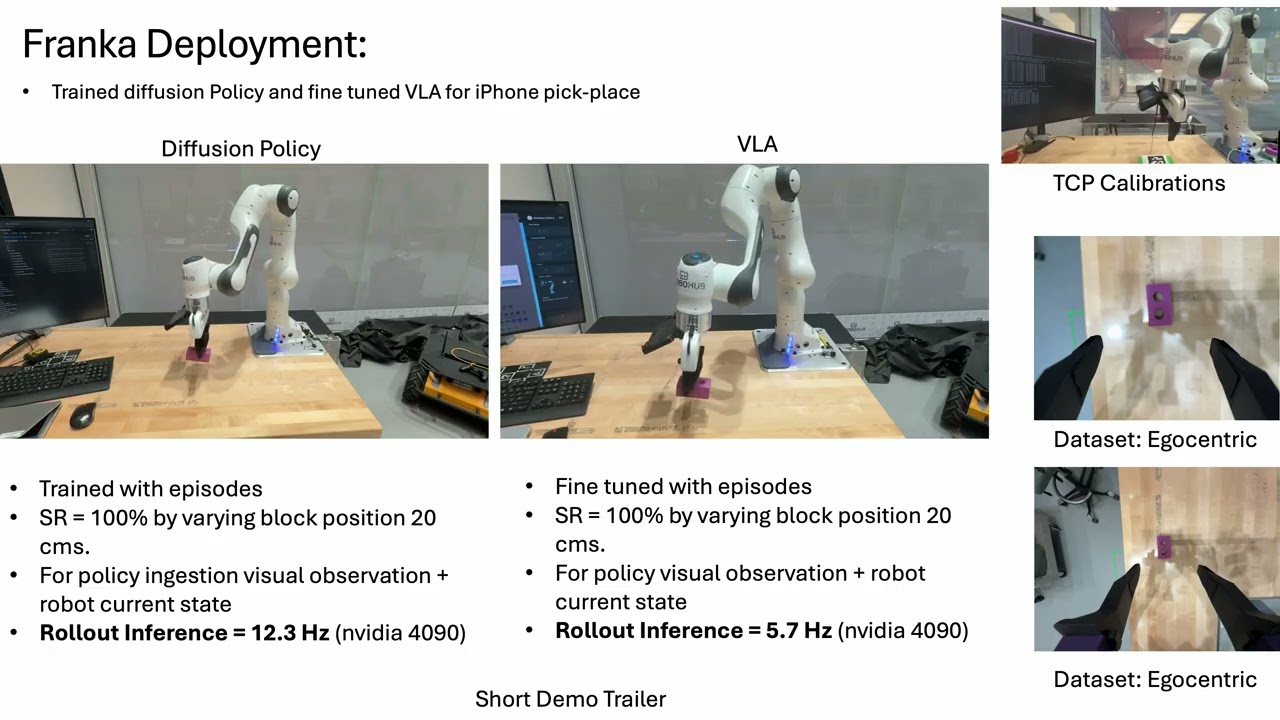
Rollout Vision-Language-Action (VLA) model after PEFT fine-tuning and Diffusion Policies on a Franka 7-DoF manipulator, learning closed-loop visuomotor control for real-world robotic manipulation tasks.
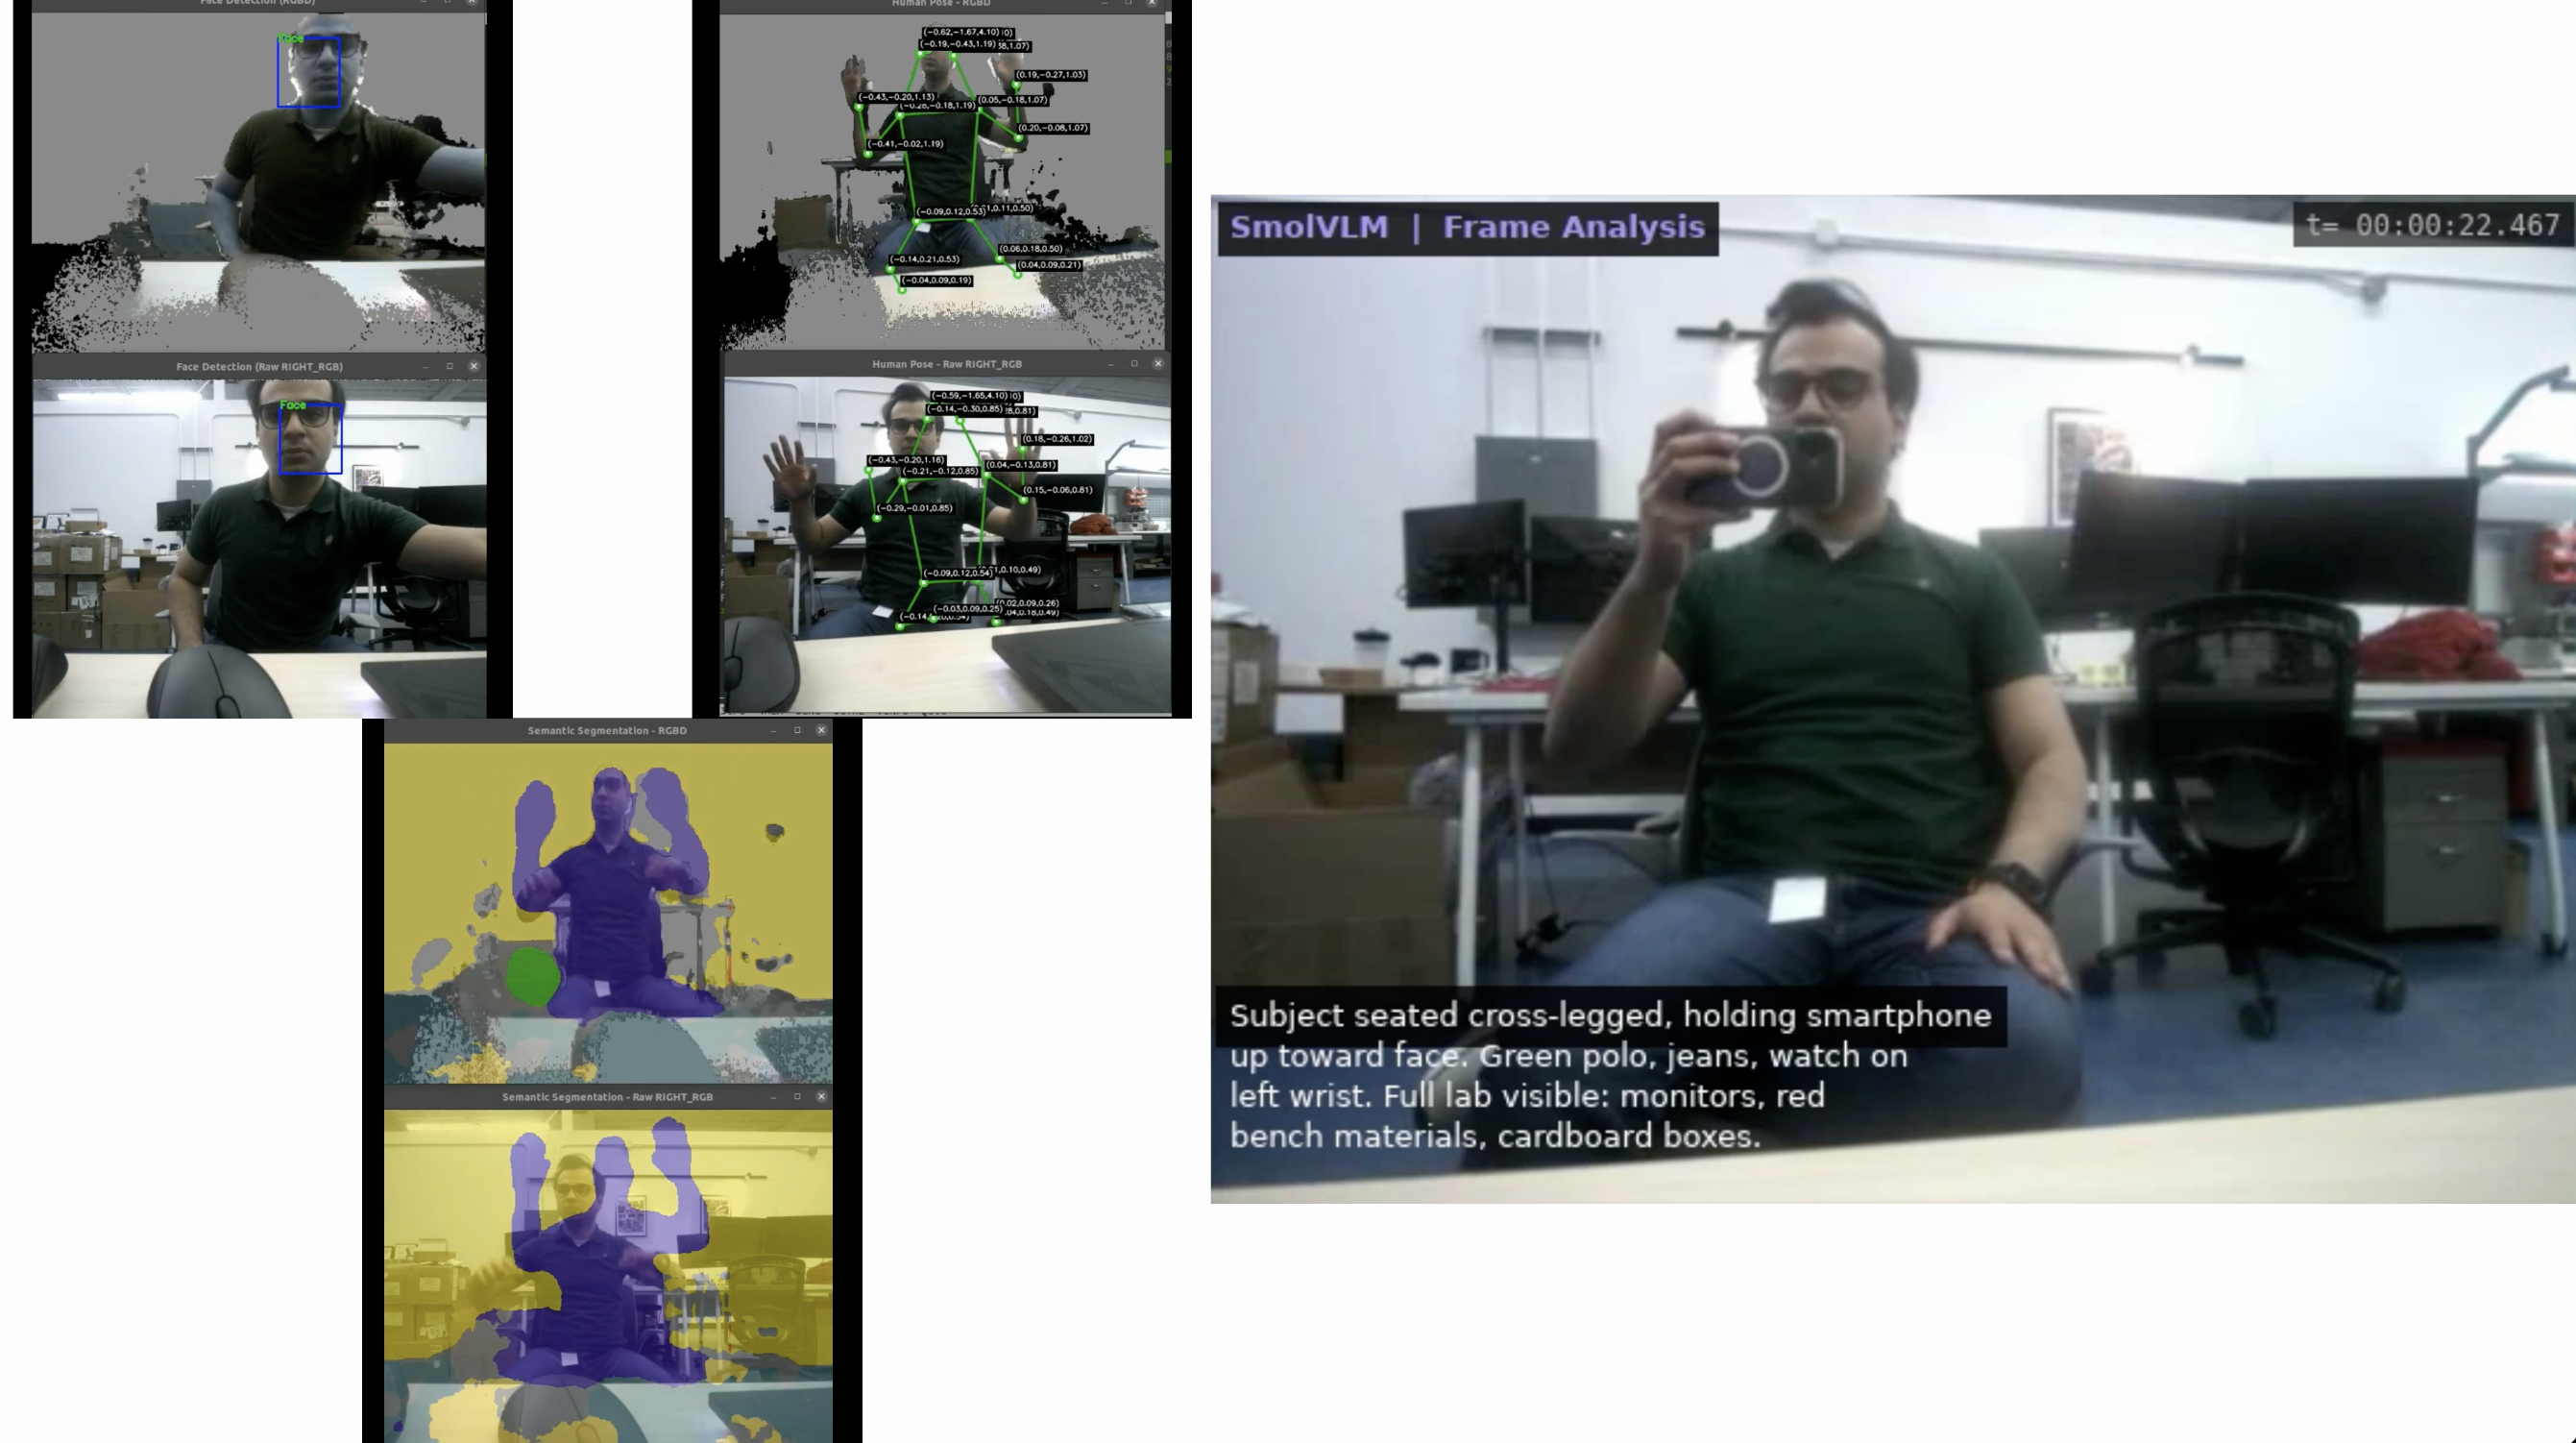
Real-time RGB-D sensor-fused multimodal pipeline (VLM, pose estimation, object detection, and semantic segmentation) built in C++ with NVIDIA CUDA, and quantized with TensorRT (FP16, INT8) for asynchronous pipelines that maximize throughput.
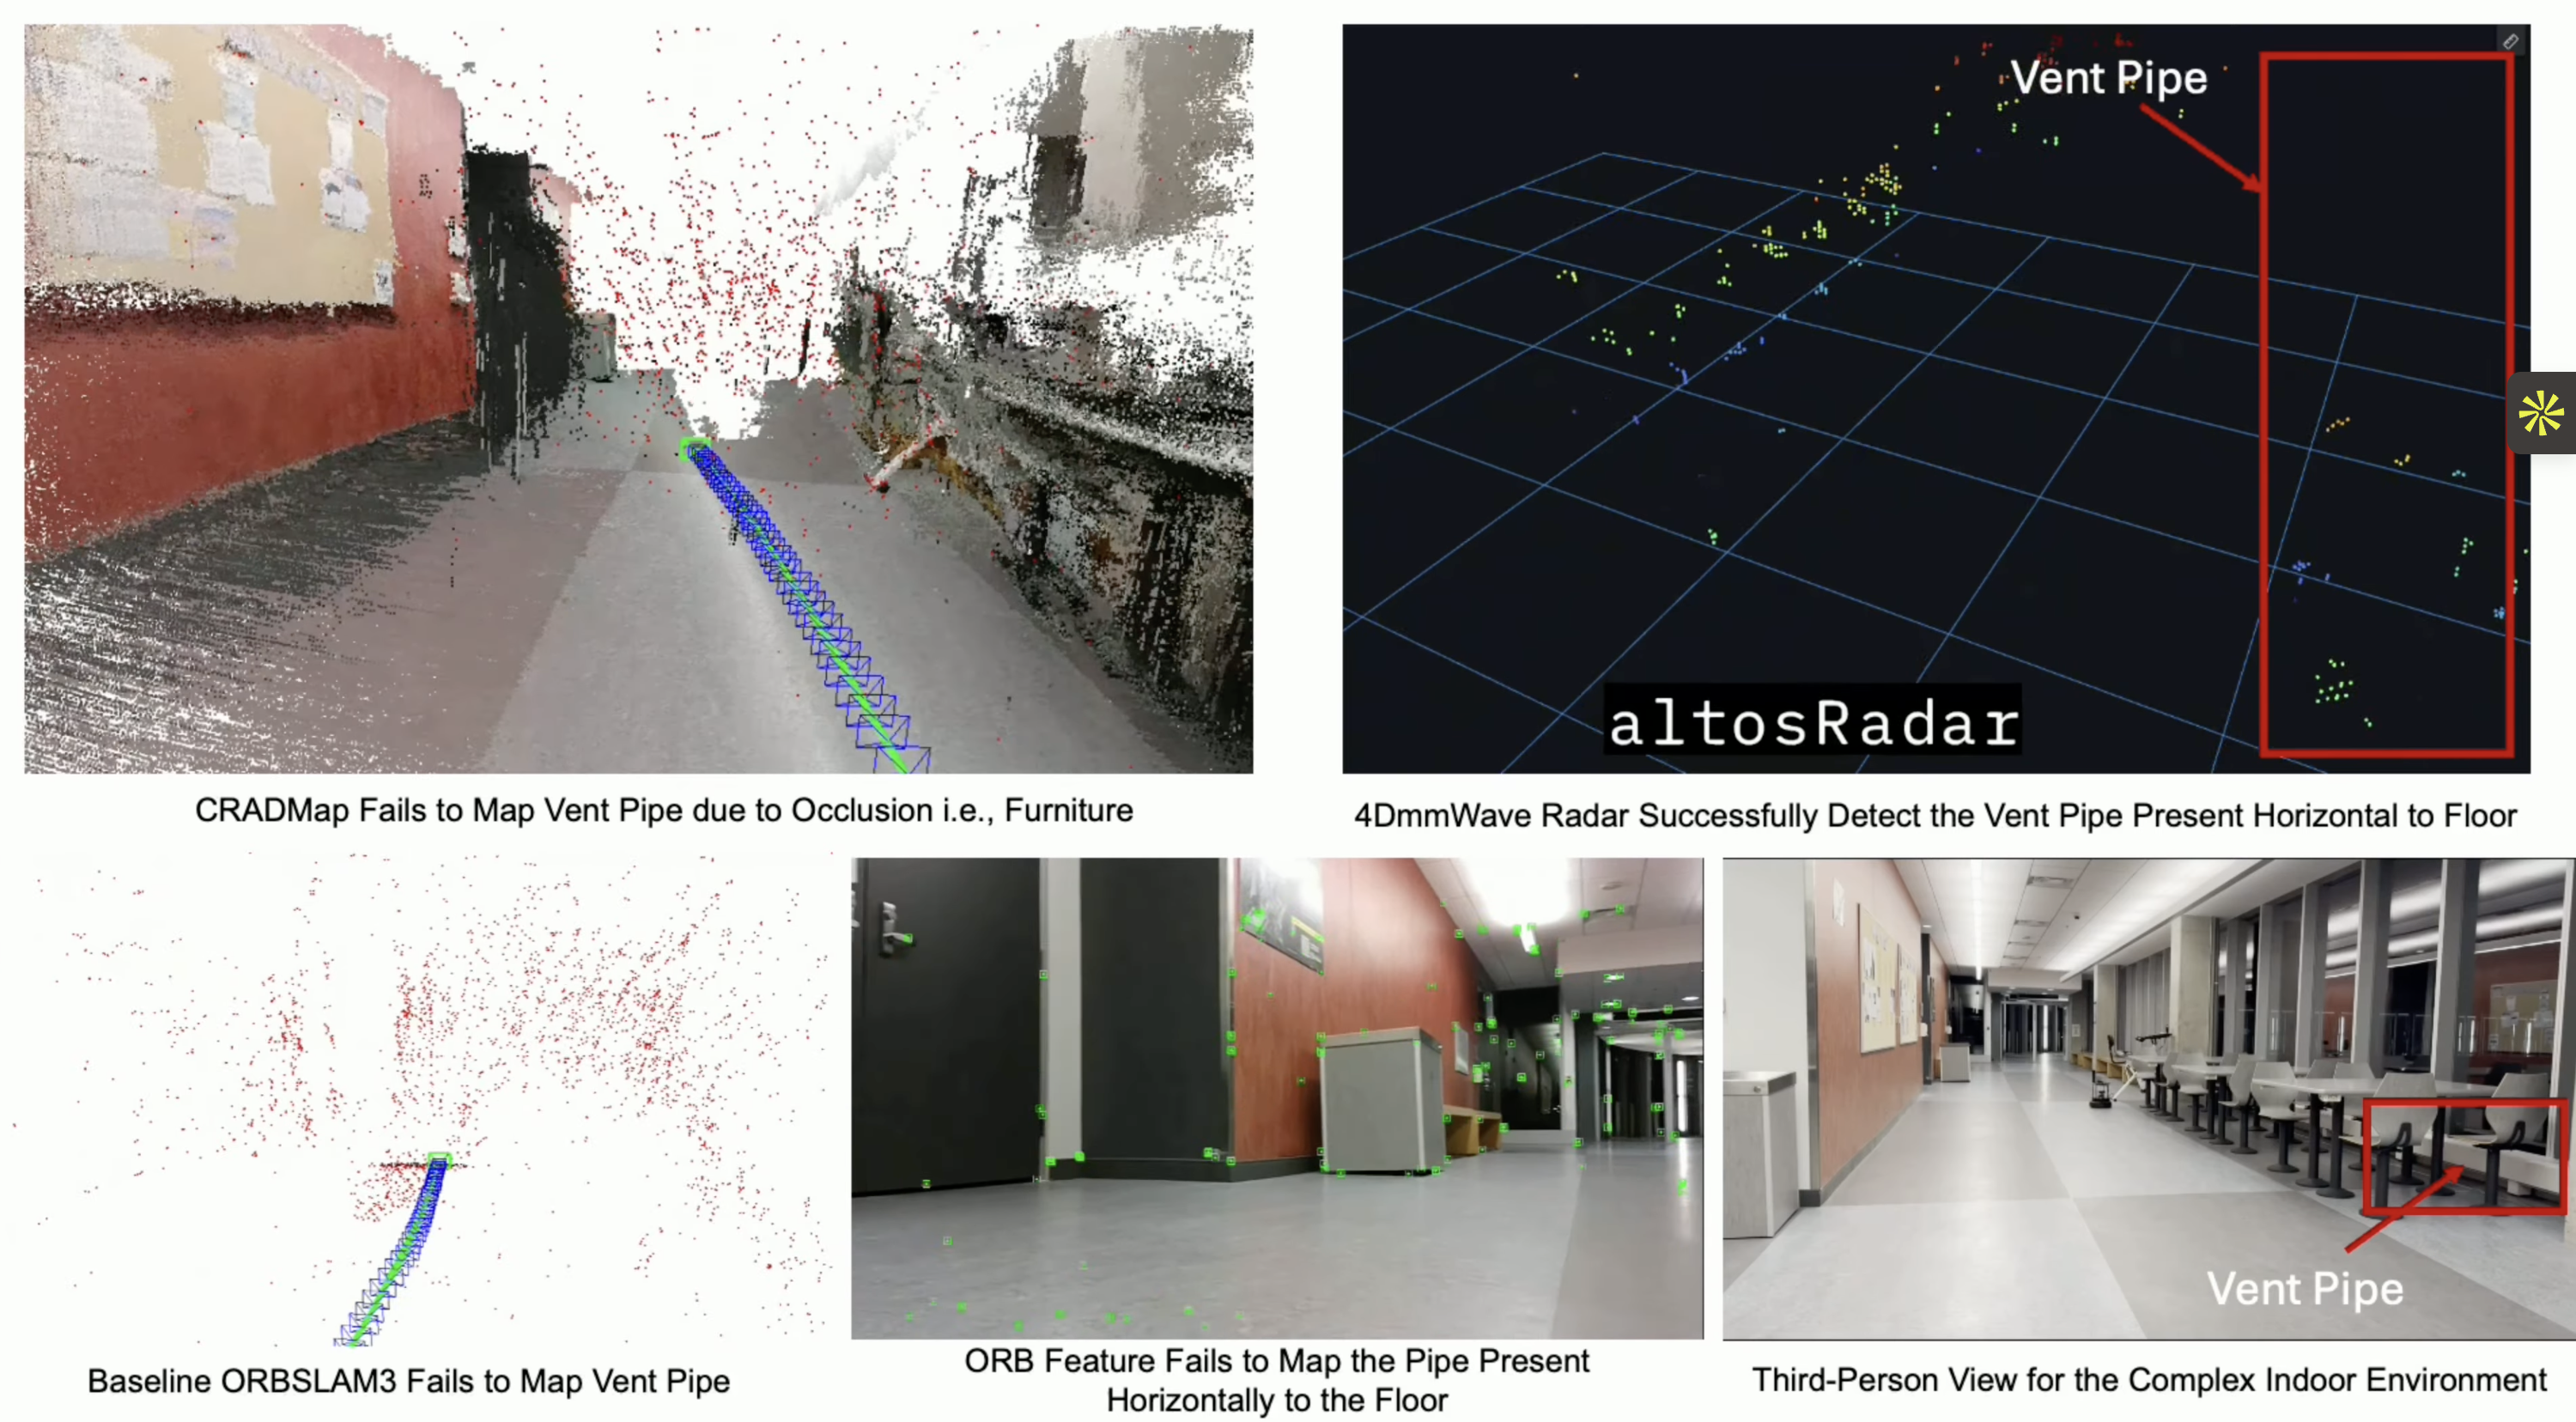
Distributed volumetric mapping integrating ORB-SLAM3 (front-end), TSDF–Octree fusion, 4D mmWave radar + RGB-D perception, and 5G offloading for real-time mapping under occlusions and degraded visibility.
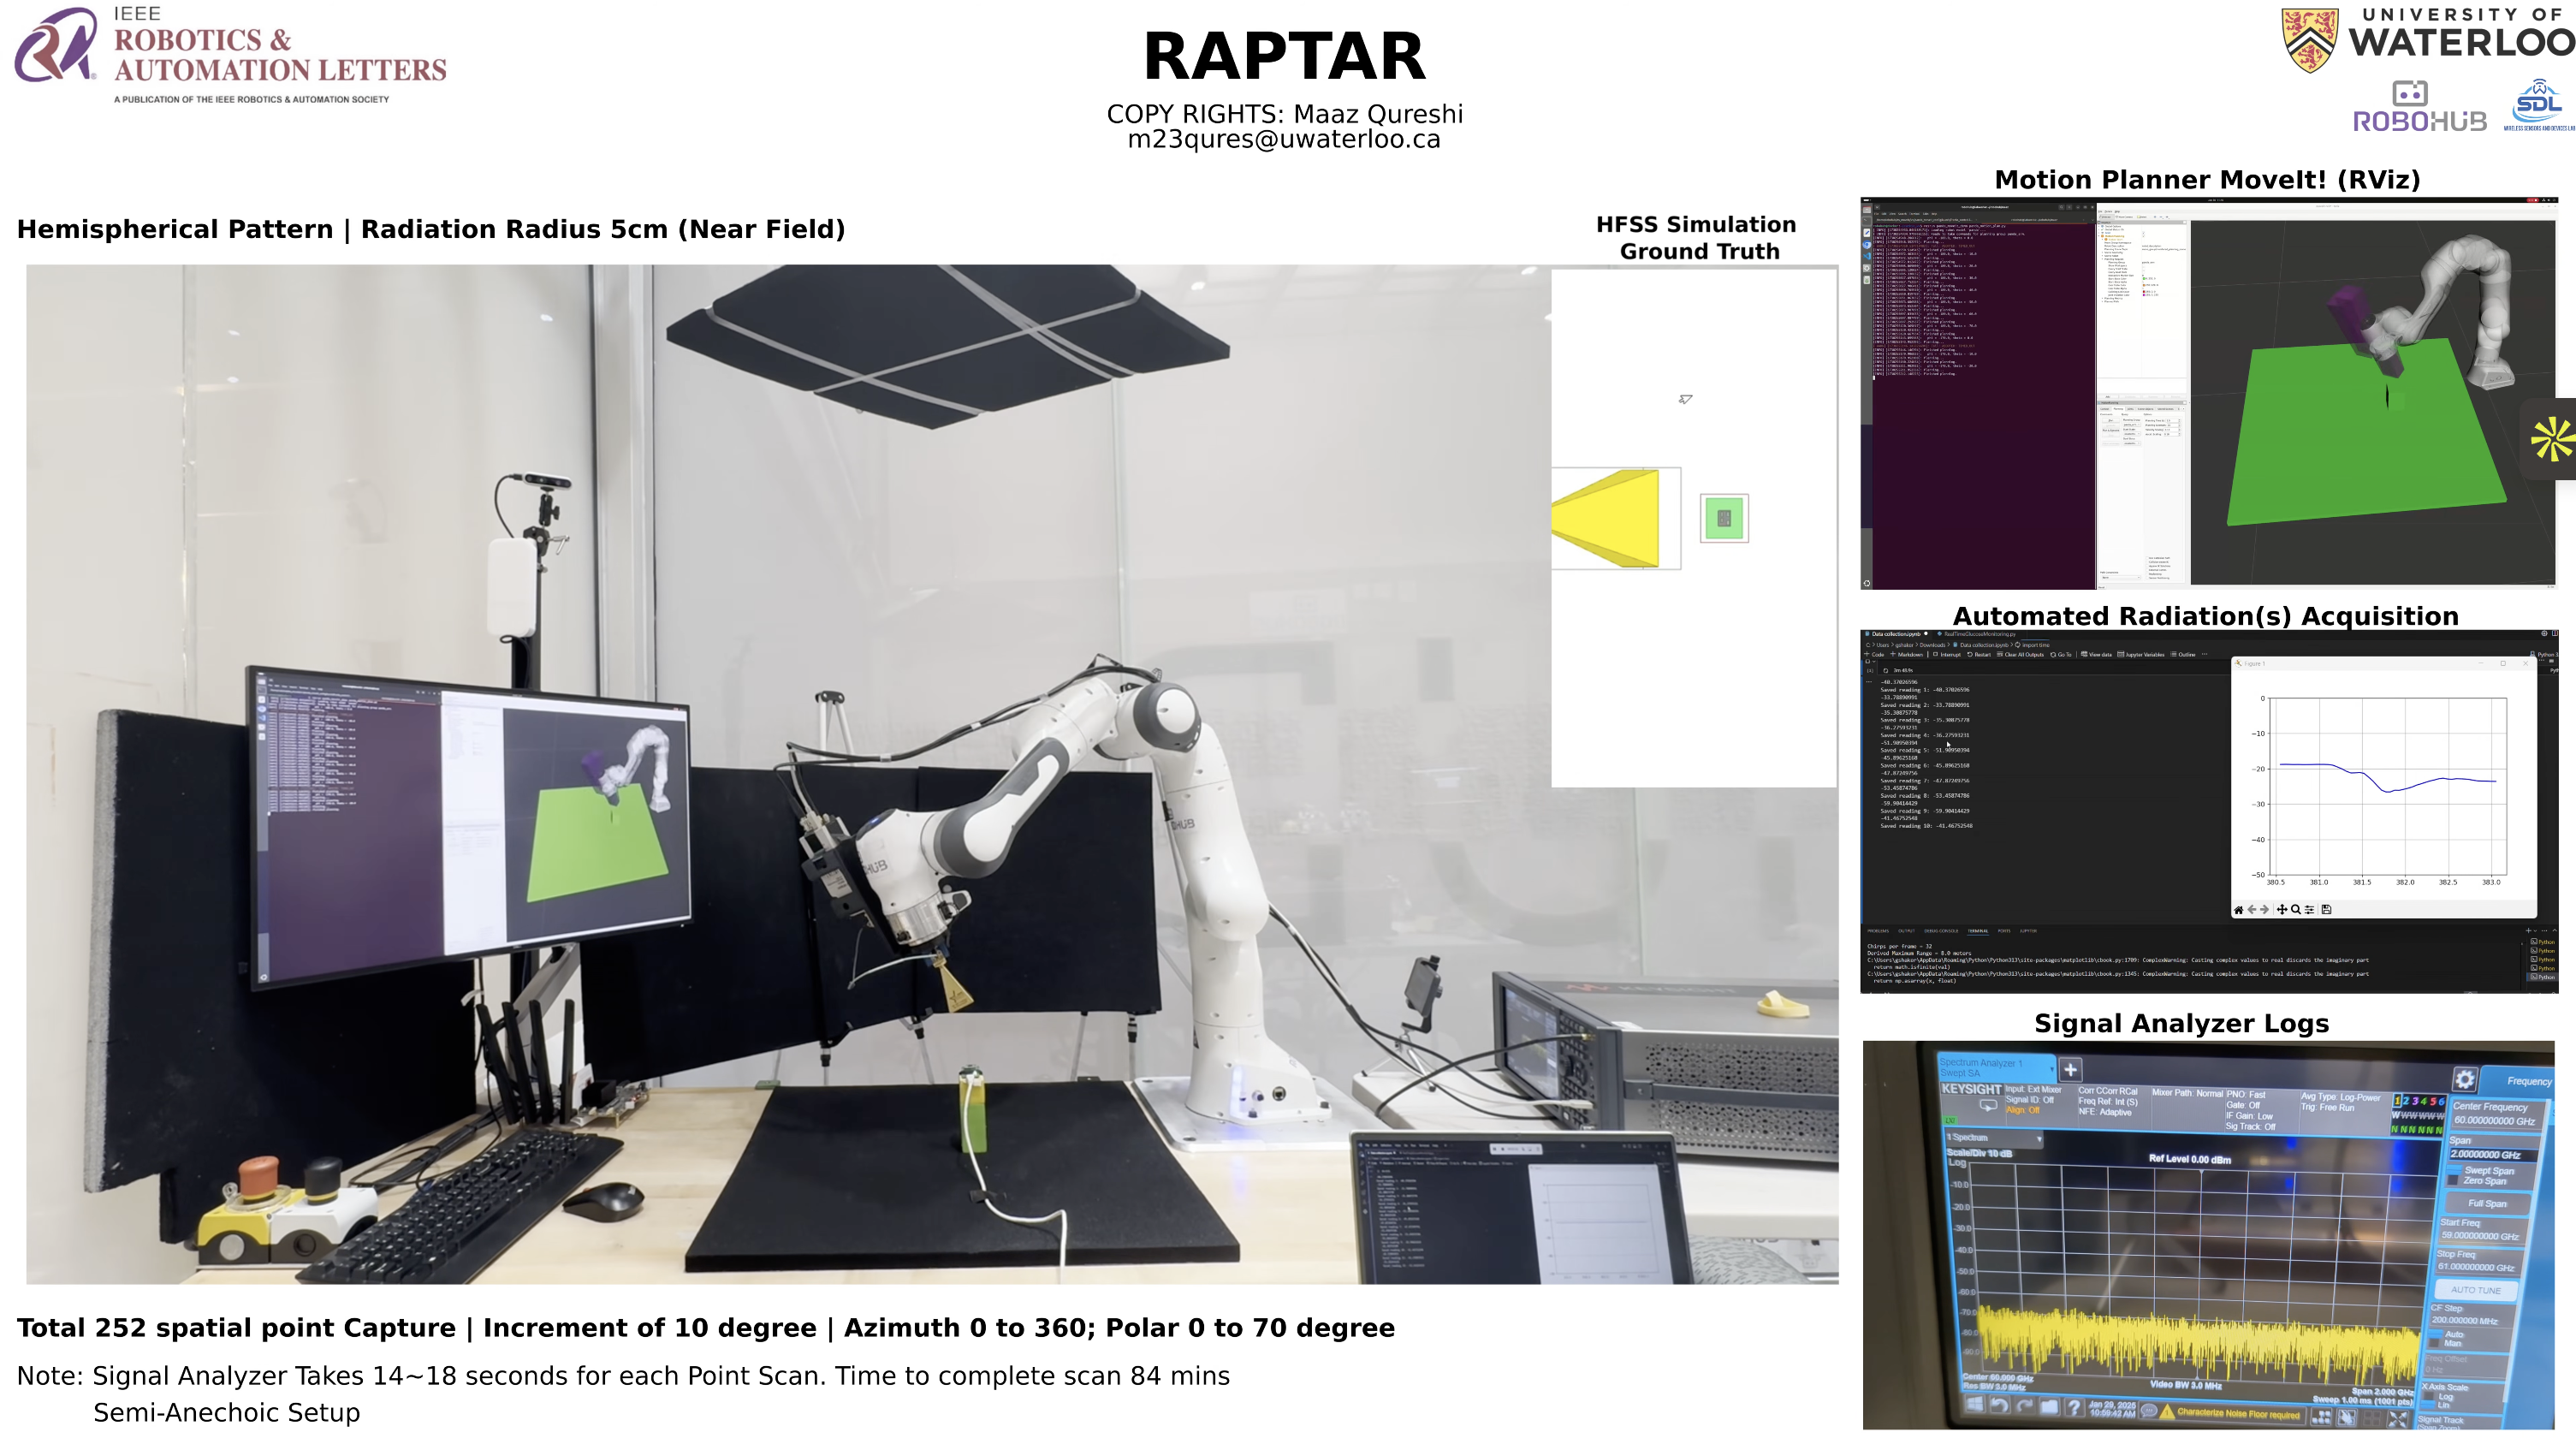
Automated collaborative-robot framework using OMPL RRT-Connect and quaternion kinematics for high-precision mmWave antenna radiation pattern measurement in 3D space.
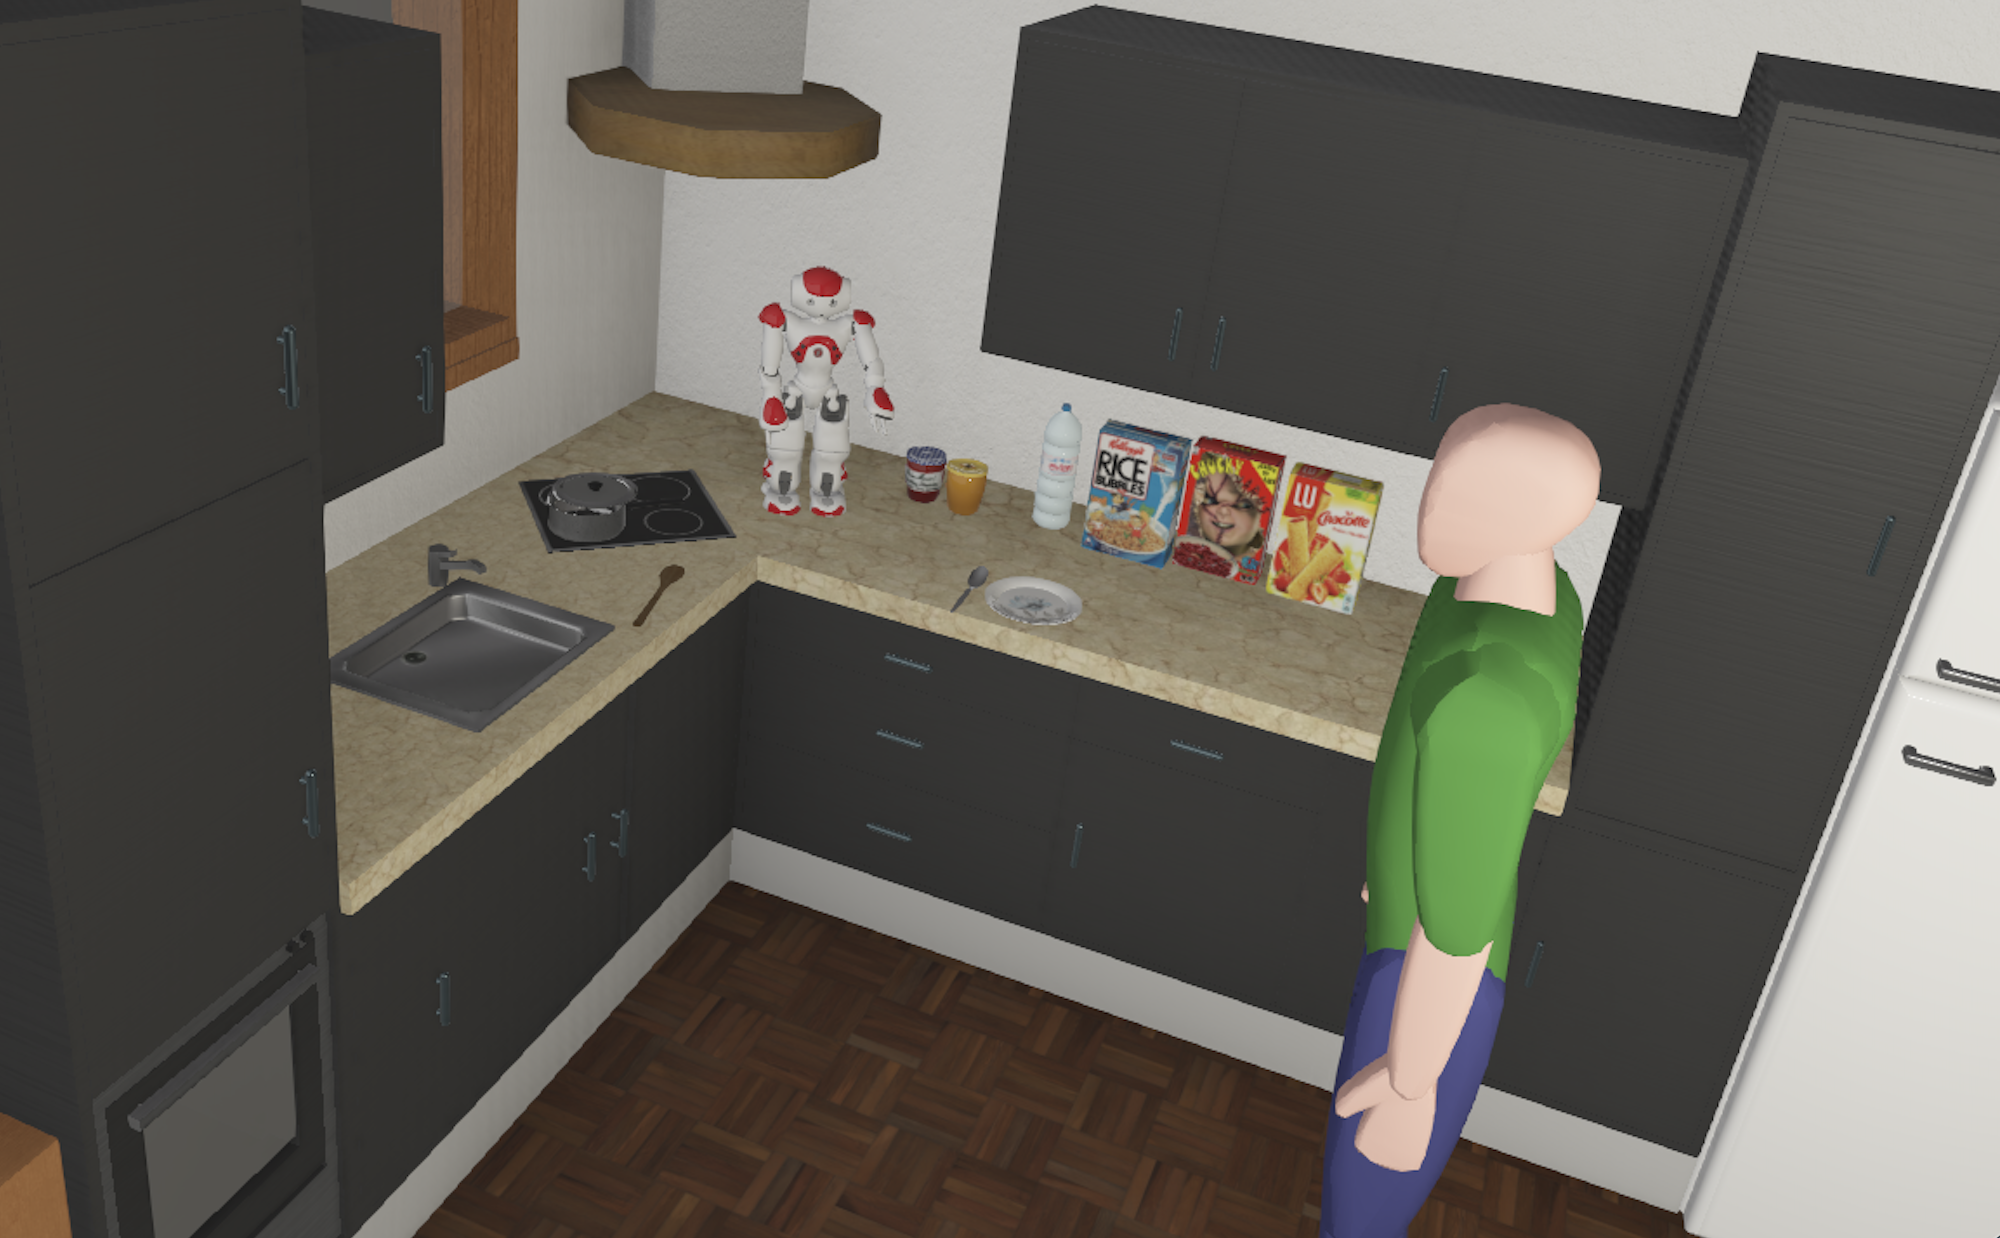
Integrated LLaMA 3 with gesture and vision sensing for real-time multimodal control of NAO robot, enabling non-verbal HRI via IMU-based motion interpretation.
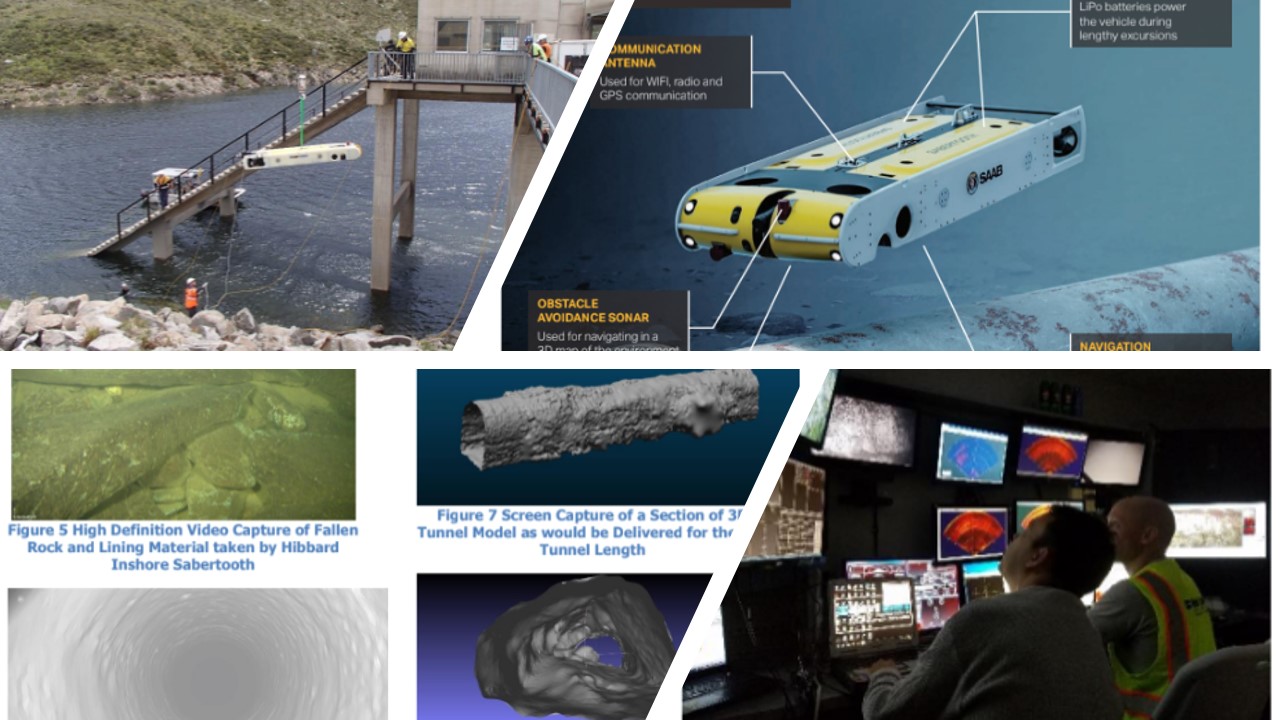
Structure inspection of the NJHEP dam using multi-beam sonar, profiling sonar, and monochrome camera on ROVs/AUVs over 18 km tethered operation, the largest inspection of its kind in Asia.
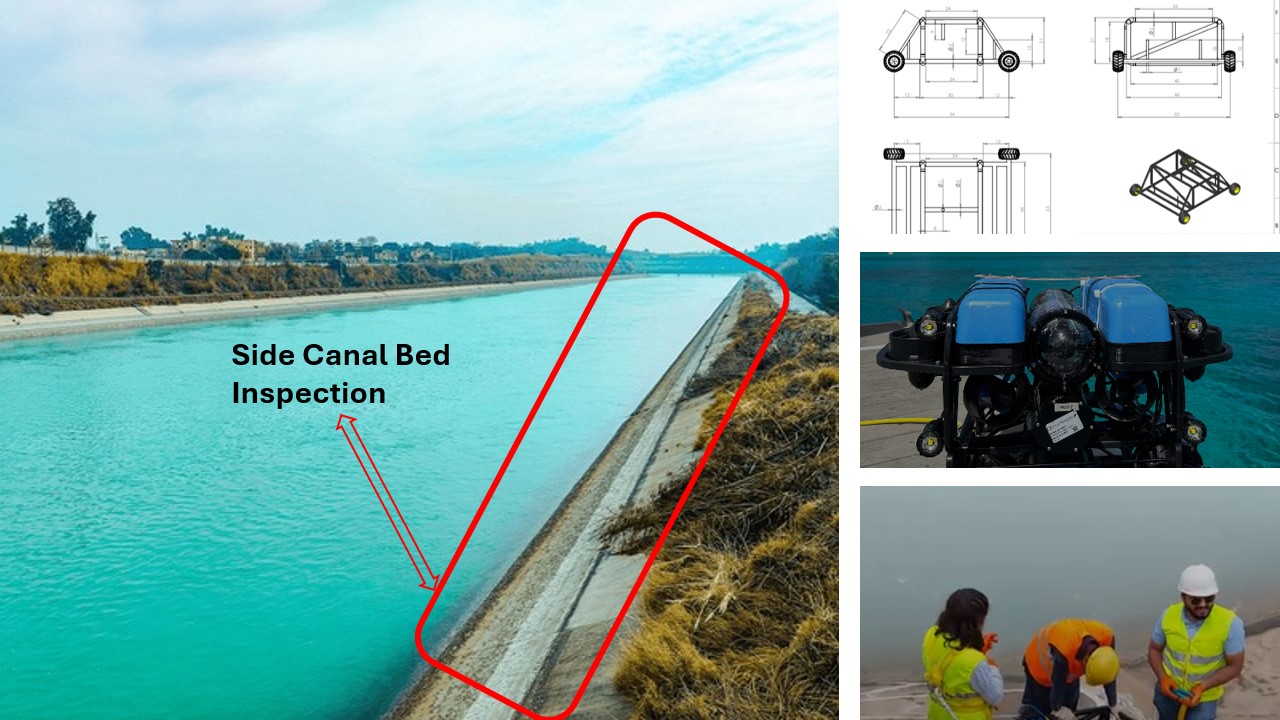
Integrated Oculus 750d sonar on a custom ROV frame and performed underwater crack-propagation analysis at 9m depth and 2.3 m/s water velocity.
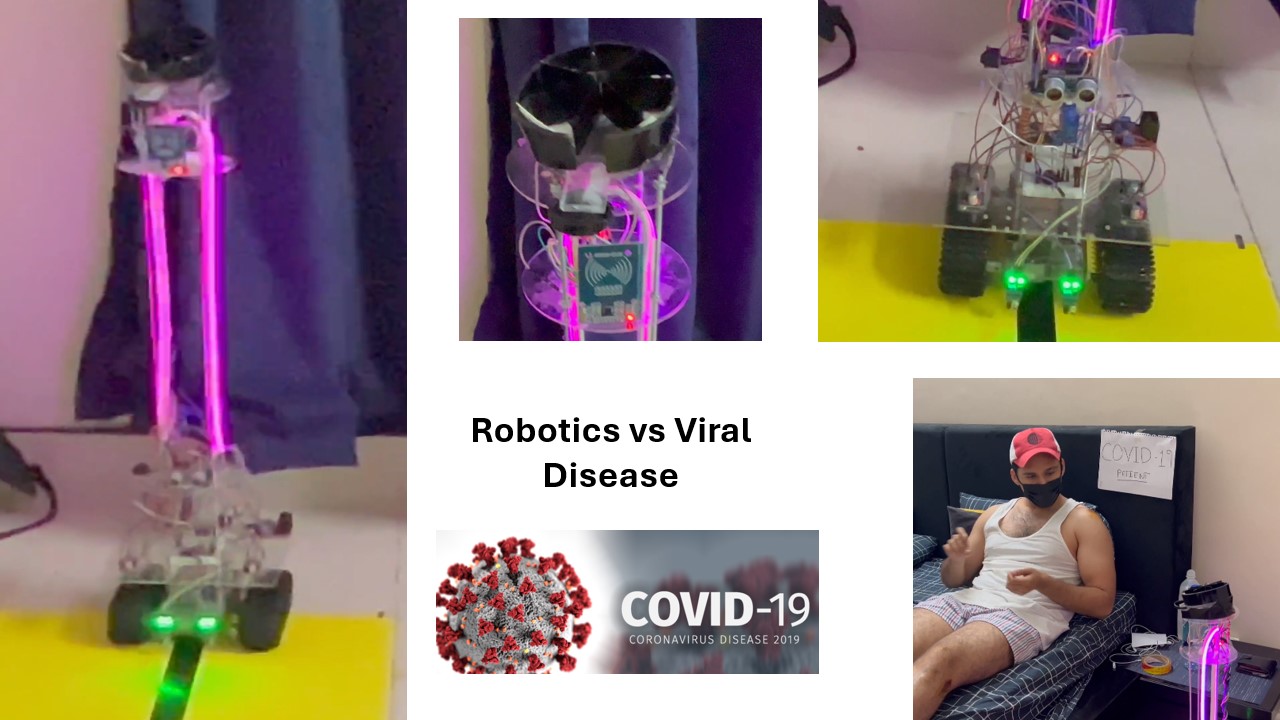
Designed an autonomous robot integrating facial recognition, RFID-based navigation, and multi-pill dispensing for safe patient-care workflows during COVID-19.